Technology Title
Tele-operated Bolting & Fastening Maintenance Innovation
Tech Focus Area
Reliability Improvement
Abstract
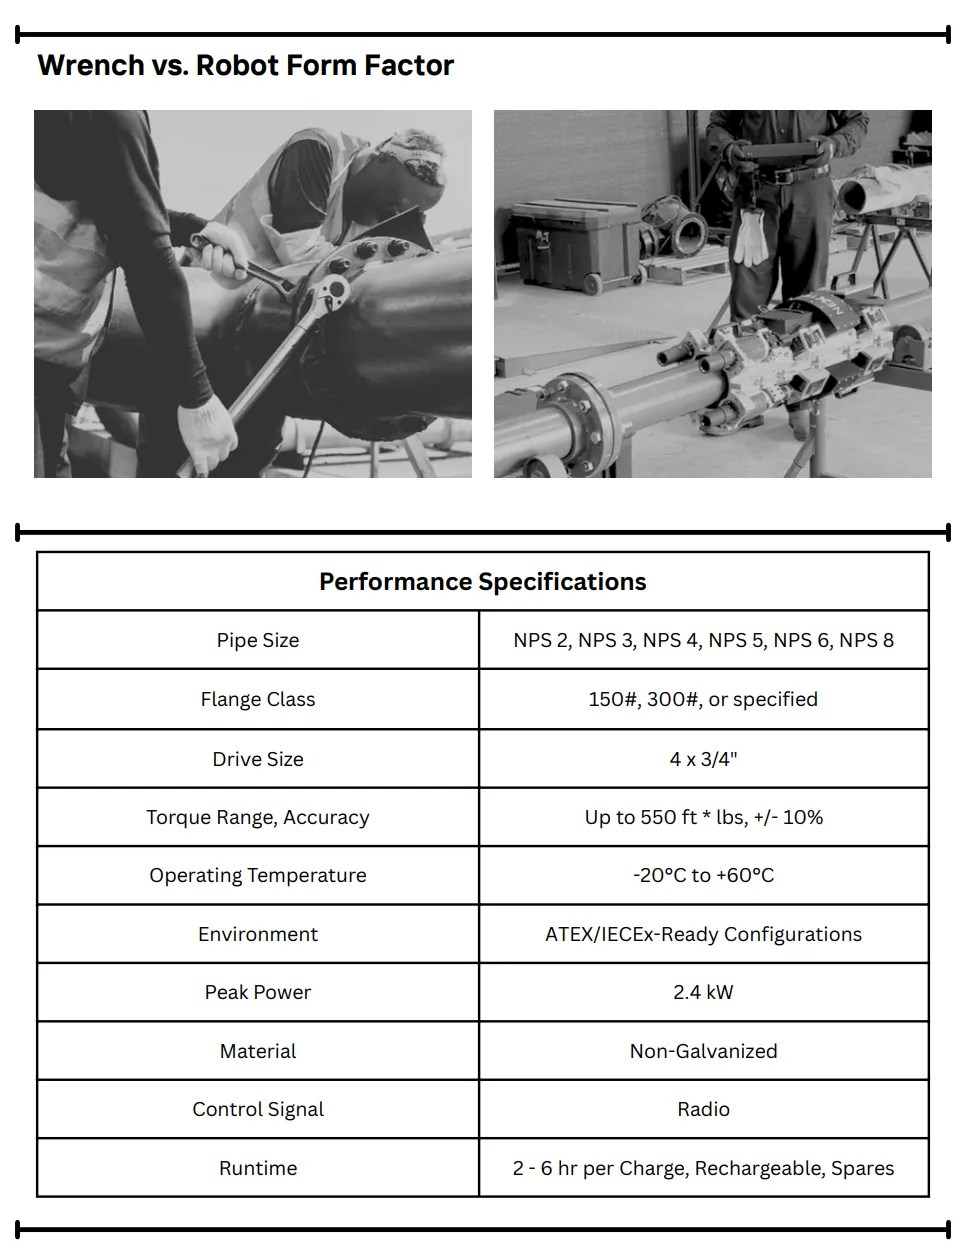
Our team develops a tele-operated robotic platform that engages four fasteners simultaneously to automate manual torquing on critical bolts and fasteners across industrial and defense infrastructure. Manual bolting today is slow, hazardous, and inconsistent: technicians work one bolt at a time at zero standoff from pressurized, hazardous equipment, with torque records still logged by hand. This technology replaces this with a lean 1-2 person, remotely operated crew that applies calibrated torque to four bolts or fasteners at once from a 10-20+ ft standoff, cutting torquing time up to 8x versus manual tools while automatically capturing standardized, audit-ready torque data for every joint.
This technology is a drop-in, human-in-the-loop tool built for existing maintenance workflows and standard flanged piping, no re-piping or fastener redesign required. It runs on industry-trusted gearbox hardware and an all-electric lithium-ion power supply (no hydraulics, hoses, or compressors), engineered to ASME PCC-1 and API 660 guidelines. Torque range is up to 550 ft-lbs at +/-10% accuracy, with ATEX/IECEx-ready configurations for hazardous environments. Automated data capture supports predictive maintenance and reliability analytics aligned with DoW sustainment priorities.
Graphic
Our team’s relationships already extend into defense. Our team also holds a U.S. Army SBIR Phase I award and counts the U.S. Army and NYC Dept. of Design and Construction among named pilot accounts, alongside industrial owners including large refining and chemical manufacturers in the US. The roadmap includes Class 1 Division 2/UL hazardous-location certification, unlocking turnaround operations in pressurized, safety-critical environments common to both industrial and military infrastructure, with a longer-term path toward full autonomy.
This technology has progressed from TRL 1 to TRL 7 in under twelve months, is backed by four filed patent applications covering the multi-fastener mechanism, includes a backup-wrench securing system, and features an ergonomic design to prevent hand injuries in tight spaces. The company has received over $375K in non-dilutive funding.
This R&D is led by Founder & CEO Lindsey Elliott, a mechanical engineer who began her career at ExxonMobil’s Baton Rouge refinery and leads ASME’s PVP CTBJ Topic 19 (AI), alongside Director of Product Shahn Andersen, a repeat robotics founder, giving the team practical insight into how bolted-joint maintenance is performed today and how it must change.
By transforming high-force, repetitive torquing into a safer, faster, data-rich process, our team and technology offers the DoW a transformative capability to reduce maintenance labor dependency, improve joint quality and worker safety, and build the structured data foundation needed for predictive sustainment, directly advancing the goals of the 2026 DoW Maintenance Innovation Challenge.